Legacy · Mechanical validation · §8.3 / Fig. 6d
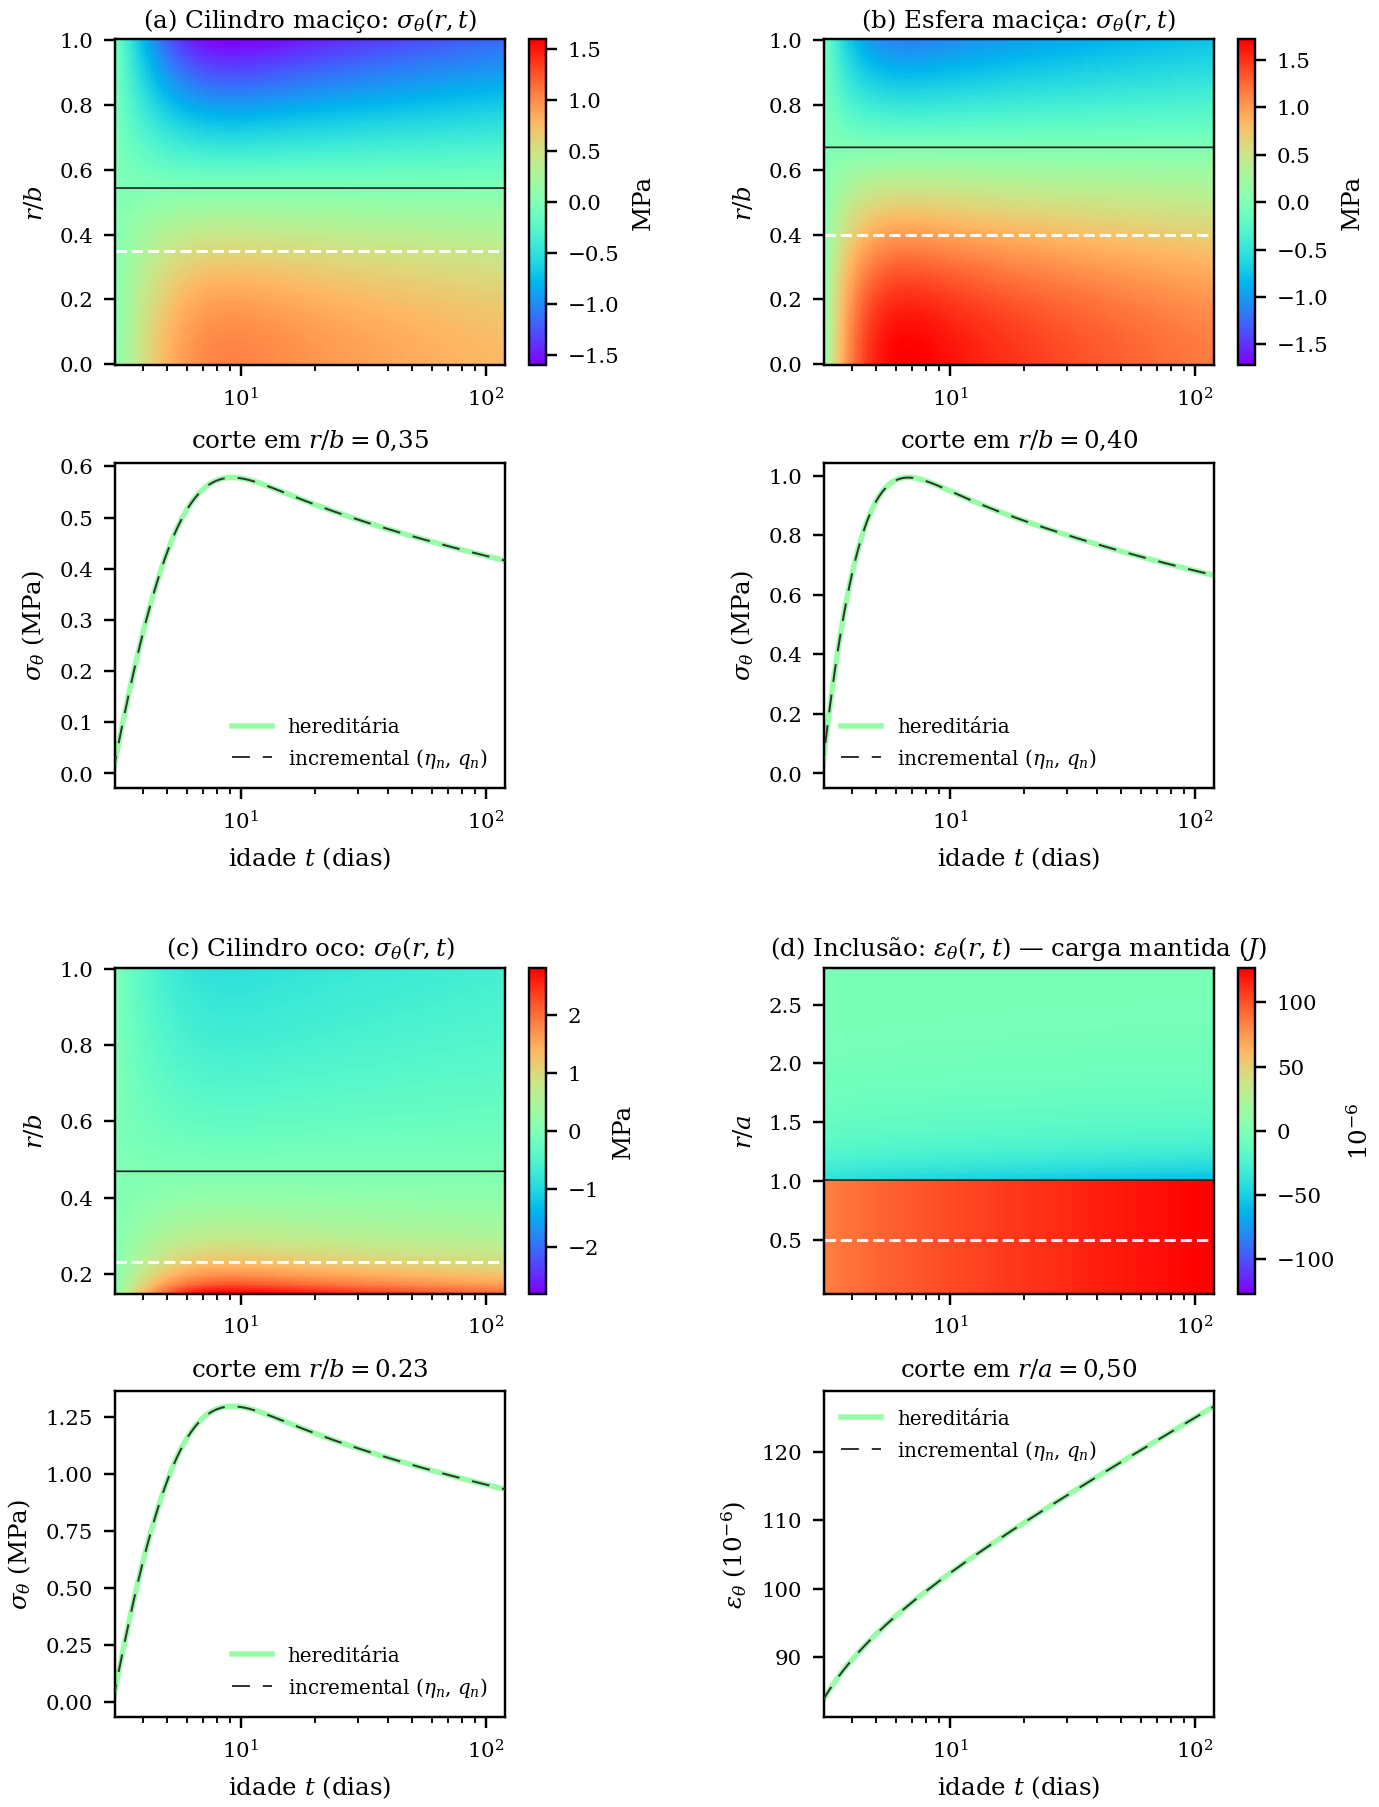
Spherical inclusion (Fig. 6d)
At the elastic stress of in the sphere is frozen and is held (stress control); grows with .
Article: Part I · DOI rirc.v1n2a007 · §8.3 / Fig. 6(d)
Mechanical material: Itumbiara — ; . Diffusivity: (do not confuse with ). Idea: ⇒ .
Control points (all Fig. 6 cases): ref_fig6_pontos_controle.csv.
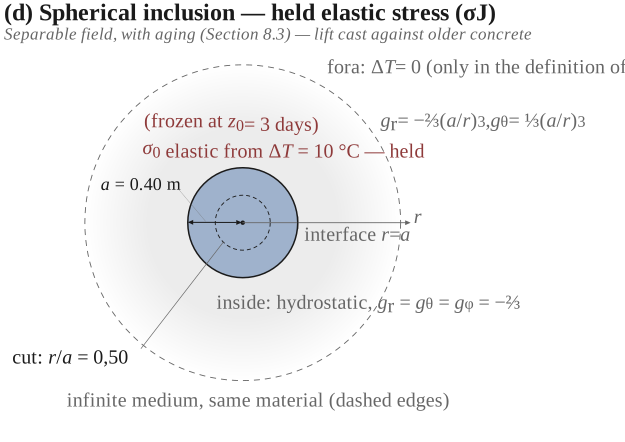
Schematic
Data sheet
| Item | Value |
|---|---|
| Geometry | Spherical inclusion of radius in an infinite medium (same material). On the portal/CSVs: (convenient scale). In the article §8.3 the drawing uses ; in coordinates the map is identical |
| Readouts | (inside) and (outside) |
| Loading | at ; frozen |
| Response |
Input files
- Material: Itumbiara — in particular
- Elastic field / : ref_inclusao_g.csv
Output figures
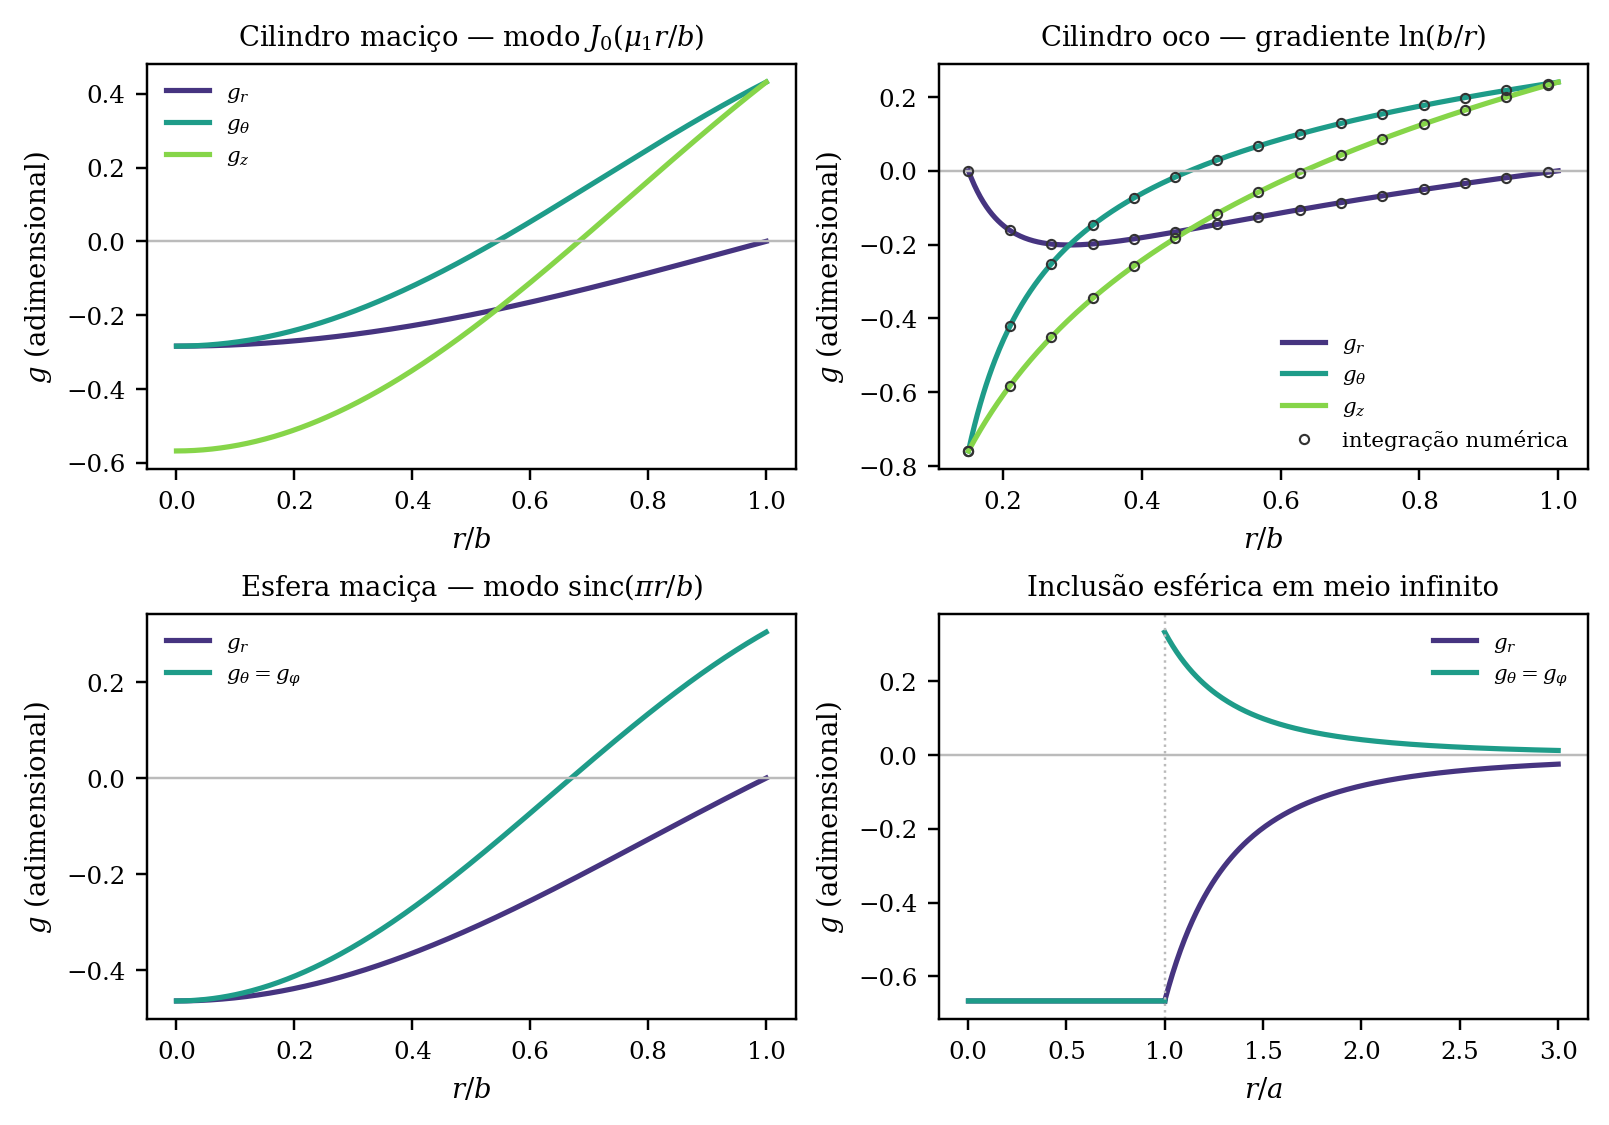 · Contours